
Epson IMU M-G370PDT UART/SPI


Free loan evaluation kits available!
Epson IMU M-G370PDT UART/SPI
The low-noise IMU for gimbals and stabilized optics: 0.03 °/√h angular random walk in a 24 × 24 × 10 mm, 10 g module.
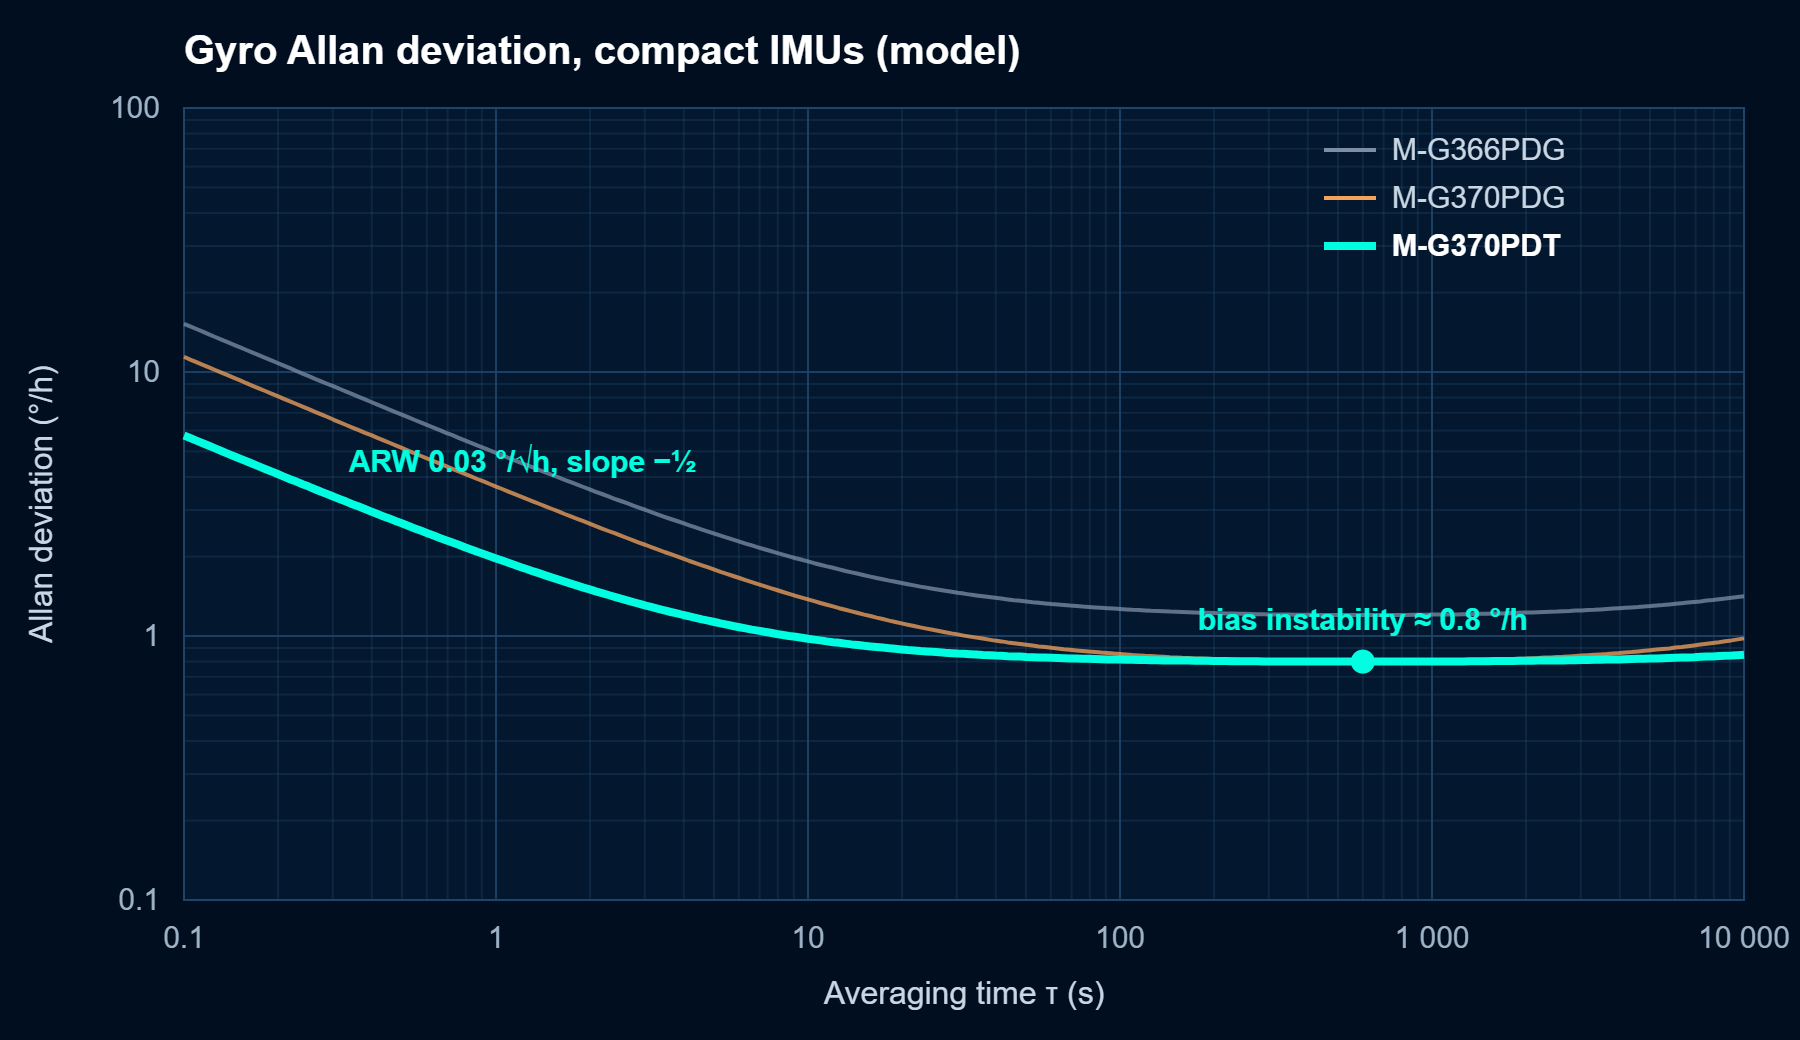
Half the angle noise of the M-G370PDG with the same 0.8 °/h bias instability. The ±200 °/s range concentrates resolution where stabilization happens.
Where the M-G370PDT fits best
Camera and EO/IR gimbals
Sharp images at long focal lengths need a calm rate signal.
Antenna and SATCOM pointing
Stable pointing on moving vehicles and vessels.
Mapping payloads
Attitude for LiDAR and photogrammetry where angle noise blurs the point cloud.
Precision navigation
Low noise and low drift for ground and aerial vehicles.
Allan deviation and key specifications
On the left of the curve the M-G370PDT is clearly quieter than the PDG models. At long averaging times it meets the M-G370PDG.
| Parameter | Typical value |
|---|---|
| Angular random walk | 0.03 °/√h |
| Gyro bias instability | 0.8 °/h |
| Gyro noise density | 2.52 (°/h)/√Hz |
| Gyro range | ±200 °/s |
| Accelerometer range | ±8 g / ±16 g |
| Accelerometer bias instability | 24 µg |
| Output rate | up to 2000 Sps |
| Interface | UART or SPI |
| Supply | 3.3 V, 16 mA typ. |
| Operating temperature | −40 … +85 °C |
| Size, weight | 24 × 24 × 10 mm, 10 g |
Typical values from the Epson data sheet. The full data sheet is available on request.
Same footprint as the PDG series
Develop with one board layout and choose the sensor by application.
M-G370PDT
Lowest noise
Frequently asked questions
M-G370PDT or M-G370PDG?
Both have 0.8 °/h bias instability. Choose the PDT when angle noise limits your image or pointing quality and ±200 °/s is enough. For vehicles with faster turns and for navigation, the M-G370PDG with ±450 °/s is usually the better fit.
Does it fit the same board as the PDG models?
Yes. It shares the 24 × 24 × 10 mm footprint and connector with the PDG series.
Can it output delta angle and delta velocity?
Yes, in addition to rate and acceleration. It also has an external trigger and counter reset input for synchronization.
Can I test it before ordering?
Yes. For qualified projects we lend evaluation kits free of charge.
Test it in your own system.For qualified projects we lend evaluation kits free of charge. Pricing and availability on request.
| Angular Random Walk (ARW): | 0.03 °/√h |
|---|---|
| Bias Instability (Accelerometer): | 24 μG |
| Bias Instability (Gyro): | 0.8 °/h |
| Country of Origin: | Japan |
| Dimension: | 24x24x10 mm3 |
| Interface (Protocol): | SPI , UART |
| Manufacturer: | Epson |
| Operating Temperature (max): | +85°C |
| Operating Temperature (min): | -40°C |
| Range (Accelerometer): | +/- 8G, +/- 16G |
| Range (Gyro): | +/-200 °/s |
| Series/ Type: | M-G370 |
| Supply Voltage, Vcc: | 3.3 V |
| Velocity Random Walk (VRW): | 0.020 (m/s)/√h |
More IMU's


